Powiedz znajomym o tym przedmiocie:
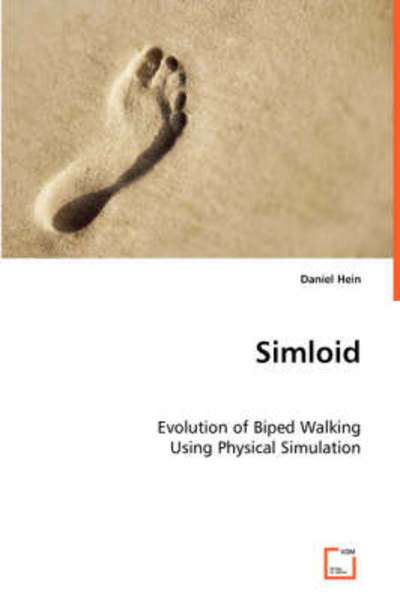
Simloid: Evolution of Biped Walking Using Physical Simulation Daniel Hein
Zamówione z odległego magazynu
 Świąteczne prezenty można zwracać do 31 stycznia

Nasi klienci mówią:
Simloid: Evolution of Biped Walking Using Physical Simulation
Daniel Hein
Controlling a biped robot with a high degree of freedom to achieve stable movement patterns is still an open and complex problem. Thus, the development of control mechanisms for biped walking have become an important field of research. With growing calculationpower of computer hardware, high resolution realtime simulation of such robot models in effect becomes all the more applicable. This thesis presents a physical simulation of a 19 degrees of freedom real biped robot model and demonstrates its application for exploring biped motion control techniques. It introduces two different approaches of biped motion generation, which specify target angle functions for all driven joints. Both approaches were developed and implemented within the physical simulation of the biped robot. Whilst the motion parameters were identified and optimized using evolutionary algorithms, several walking patterns could be generated, allowing the simulated robot for covering finally more than 10m within 25s.
| Media | Książki Paperback Book (Książka z miękką okładką i klejonym grzbietem) |
| Wydane | 2 lipca 2008 |
| ISBN13 | 9783639053302 |
| Wydawcy | VDM Verlag |
| Strony | 112 |
| Wymiary | 150 × 220 × 10 mm · 158 g |
| Język | Angielski |